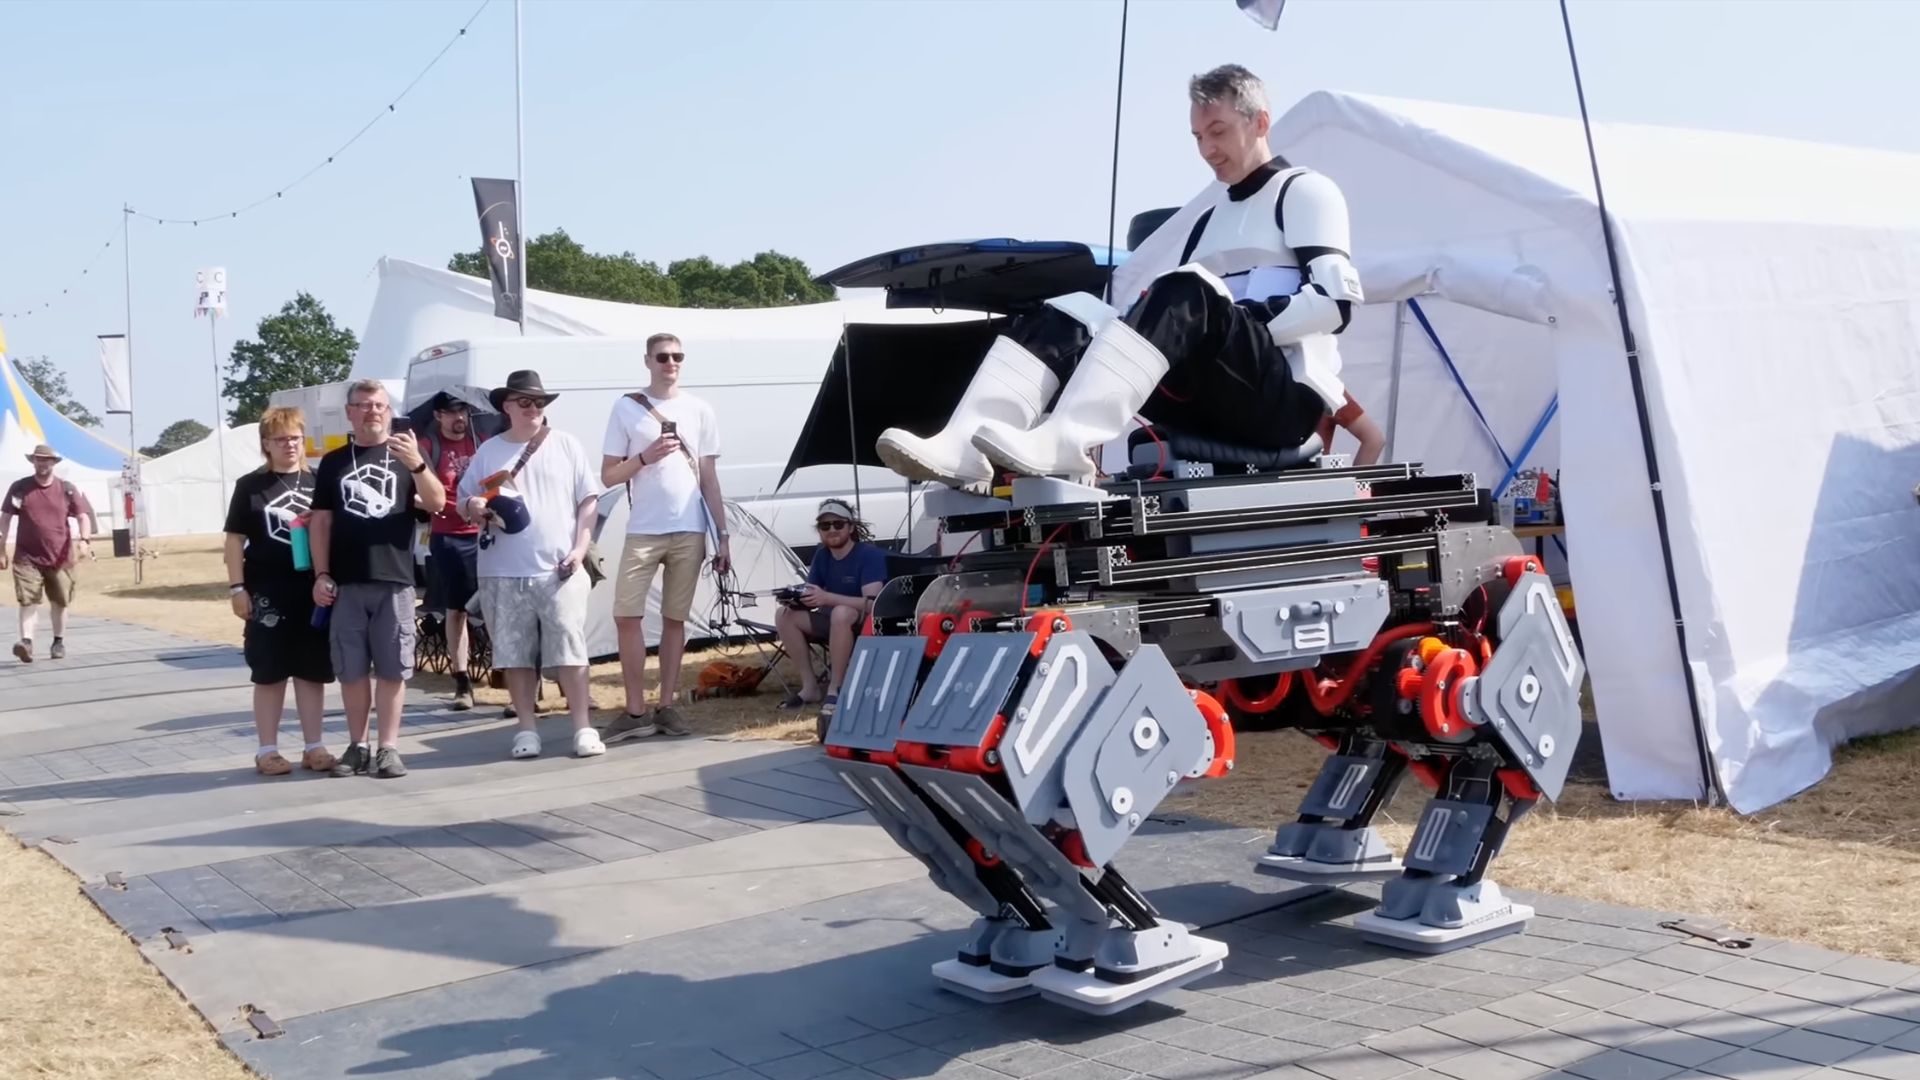
The world of robotics is an ever-evolving landscape, and one of the most exciting areas of development is the creation of quadruped robots capable of carrying humans. YouTuber James Bruton has been at the forefront of this innovation, and his latest creation, the Mid-Walker, is a testament to the progress being made in this field. However, as Bruton discovered, there are still significant challenges to overcome before these robots can become a reality. In this article, I will explore the Mid-Walker's design, the challenges it faces, and the potential solutions that could bring us closer to a future where robots can carry humans across long distances.
The Mid-Walker: A Quadruped Robot with a Human-Carrying Capacity
The Mid-Walker is a small quadruped robot designed to carry a rider. Its diagonal legs are mechanically connected, causing them to move in pairs, which leaves two feet on the ground at any time, making the machine stable on level surfaces. This design is a significant improvement over previous models, which struggled with stability on uneven ground. Bruton's latest creation is a testament to the progress being made in robotics, and it is an exciting development for those interested in the future of human-robot interaction.
Challenges with Uneven Ground
One of the major challenges with the Mid-Walker's design is its inability to handle uneven ground. When the ground changes height, a foot landing in a dip can shift the machine's weight and cause it to tip. This is a significant issue, as it limits the robot's ability to navigate through natural environments. Bruton has explored several solutions to this problem, including adding a sliding section beneath the seat to counter this movement and using hard feet with simple wedge-shaped plywood soles.
The Limitations of Hard Feet
While the hard feet reduced the electrical load the motors needed to support the machine, they still struggled to sit properly when the ground was uneven. This left the quadruped vulnerable to sudden changes in terrain, which is a critical issue for any robot designed to carry a human. The rigid soles were simply not up to the task of navigating through natural environments, and this limitation was exposed during field testing at Electromagnetic Field Camp.
Inspiration from Bean Bags
Bruton turned to an everyday object for inspiration: the bean bag. When a person sits on one, its loose filling shifts and becomes packed beneath the load. He wanted to reproduce that behavior in the Mid-Walker's feet, allowing them to change shape before becoming firm under the machine's weight. This is a fascinating approach, and it is an example of how everyday objects can be adapted for use in robotics.
The New Feet Design
The new feet use fabric coverings combined with airtight, waterproof ripstop kite material. Their openings are secured with TPU-printed drawstrings, and they are filled with dried beans and 3D-printed 20-sided dice. The dice were cheaper to produce himself and provided triangular faces that gave the beans additional surfaces to grip. This design is an innovative solution to the problem of uneven ground, and it is an exciting development for those interested in the future of robotics.
Field Testing Reveals Limits
At Electromagnetic Field Camp, the Mid-Walker moved smoothly across level grass and trails. However, trouble began when a foot landed inside a hollow. The beans shifted, causing the sole to curl and the machine to roll over. Overfilling the feet made the problem worse, while reducing the filling by half and adding zip ties offered only limited improvement. This field testing revealed the limits of the current design and highlighted the need for further development.
A Tougher Foot Design
The experiments showed that the filling needed to move enough to conform to the ground while remaining stable under heavy loads. The dice could not prevent shifting when the machine leaned, and the plastic coverings eventually failed under stress. Bruton ultimately moved toward a more durable cloth construction for the feet. This is a practical solution, and it is an example of how robotics can be improved through iterative development.
Self-Leveling Ankles: The Next Step
Bruton believes that smaller particles, such as BB pellets, could improve the locking effect, while vacuum systems could make the feet rigid after they conform to the ground. However, he favors a simpler approach. His next design will use passive two-way pivot ankles that can self-level before bar clamps lock them in place. Load cells or an inertial sensor could detect firm contact and trigger the clamps without adding another motor to the walking system. This is a fascinating development, and it is an example of how robotics can be improved through innovation.
Conclusion: The Future of Human-Robot Interaction
The Mid-Walker is an exciting development in the field of robotics, and it is an example of how everyday objects can be adapted for use in innovative ways. While there are still significant challenges to overcome, Bruton's work is an inspiring example of how robotics can be used to improve human-robot interaction. As we look to the future, it is clear that robots will play an increasingly important role in our lives, and it is exciting to think about the possibilities that lie ahead.